
Preprint · Submitted to IEEE Transactions on Robotics
arXiv v1: September 11, 2026.
Enduo Zhao, Xiaofeng Lin, Yifan Wang, Yuhan Song, Weihan Li, Saul Alexis Heredia Perez, Kanako Harada
Overview
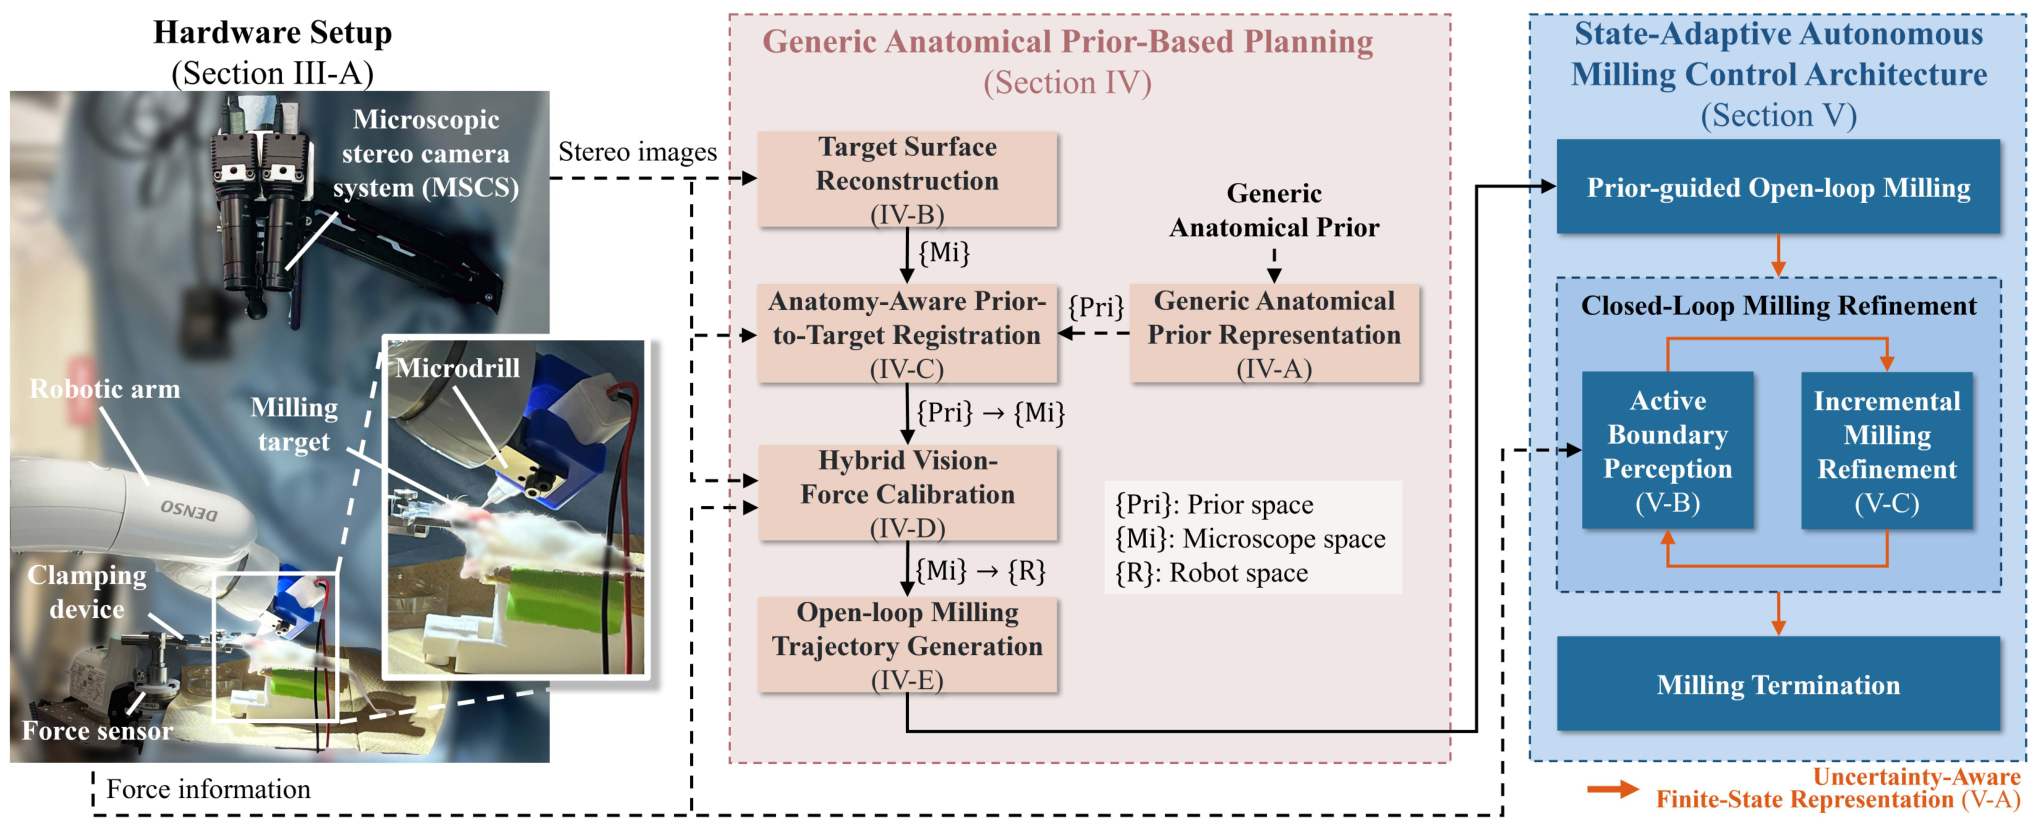
This study combines a shared anatomical model with active probing to guide autonomous milling when geometry, thickness, and tissue boundaries are uncertain. Semantic registration and vision–force calibration transfer the prior to the robot. Relative changes in stiffness then guide local refinement and the decision to stop.
Experimental evidence
The paper reports successful window creation in 20/20 surrogate trials versus 5/20 with open-loop control, and 15/15 in vivo mouse trials. Superficial bleeding occurred in 10 mouse trials and required hemostatic pauses; no dura-mater injury was observed.
Research scope
These are preclinical results. The framework assumes a relatively stable target; physiological motion and bleeding remain outside its explicit model, and iterative refinement adds execution time.
Paper and resources
arXiv:2609.12530 · PDF · arXiv DOI
System overview: Figure 2 of the paper. View full-size figure